Background
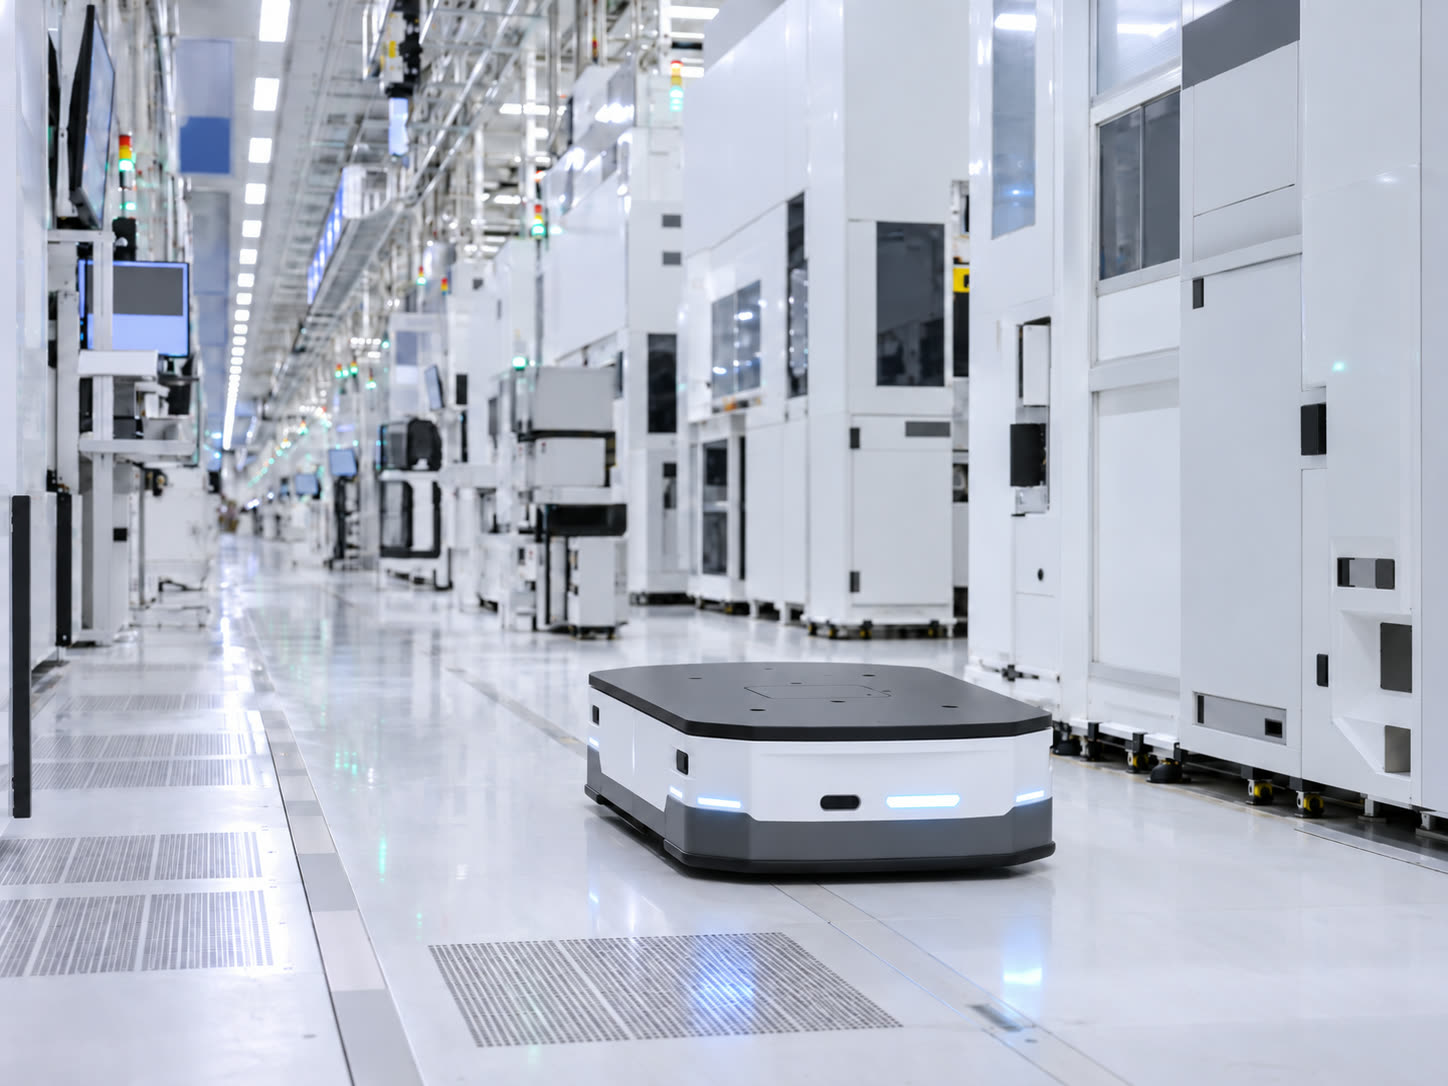
Autonomous mobile robots were deployed to move material between stations inside and outside the cleanroom, as part of a company-wide effort staffed from the automation and operations teams. My part was validating the robots and their transport routes in the working environment.
Validation Testing
I ran more than 10 test runs across the transport routes to verify that each route was unobstructed and completed repeatably. The work included the safety signage and navigation markings that define where the robots travel, and coordinating material movement with the operations teams sharing those routes.
Fault Documentation
I documented each fault seen during the runs with its location and conditions, so it could be corrected before the robots carried production material.
Network dropouts
Specific locations along the routes dropped connection more often than others. I recorded those spots with video, so the problem could be tied to a location rather than reported as intermittent.
False obstacle detections
The robots detected obstacles that were not present, stopping on clear routes and making sudden course corrections that cost travel time. I recorded where each robot departed from its mapped route, so the behavior could be worked as a mapping and detection problem rather than as random stops.
Transition faults
Faults at the route transitions where the robot hands off with facility equipment before it can pass. I documented which transitions faulted and what the robot was doing at the time.
Result
The runs produced location-specific fault records for the deployment team. The AMR fleet was subsequently expanded to additional areas.